Technical Specifications
≤10cm
Position error
≤1°
Heading error
≥60%
Environment change with positioning still held
Key Features
3 features3DGS Map & Lightweight Link
A dense 3D Gaussian Splatting map is built from video and LiDAR, and a lightweight protocol to the server keeps it real time as the fleet grows.
Learn more ↓Instant Recovery from Position Loss
When the position is lost, one camera image is sent to the server, the 6-DoF pose is computed, and driving resumes.
Holds Through 60% Environment Change
Positioning holds even when the layout no longer matches the map — within 10 cm and 1°.
Solving the Camera's Weak Spots: 3DGS Map and Lightweight Link
The camera approach's weak spots — mapping, processing and transfer load, lighting changes — are solved with a 3D Gaussian Splatting map and a lightweight link. The server does the heavy matching; the robot sends only light features.
- Mapping: 3DGS from LiDAR + video — less effort, denser data
- Processing & transfer: a lightweight server ↔ robot protocol stays real time as the fleet grows
- Lighting & environment: multi-view, multi-lighting 3DGS rendering builds a DB for many conditions
From Lost Position to Recovery: Instant Re-localization from One Camera Image
Until now, a robot that lost its position needed an operator to re-place it by hand, and work stopped in the meantime. Navi-VPS finds a similar scene from a single camera image, computes the 6-DoF pose and updates the position on the map at once, so driving resumes.
- ① Build the map: a 3DGS map from video + LiDAR
- ② Find & match: one camera image queries the server
- ③ 2D–3D registration: 6-DoF pose by PnP
- ④ Recover & resume: automatic, no operator needed
Compatibility & Integration
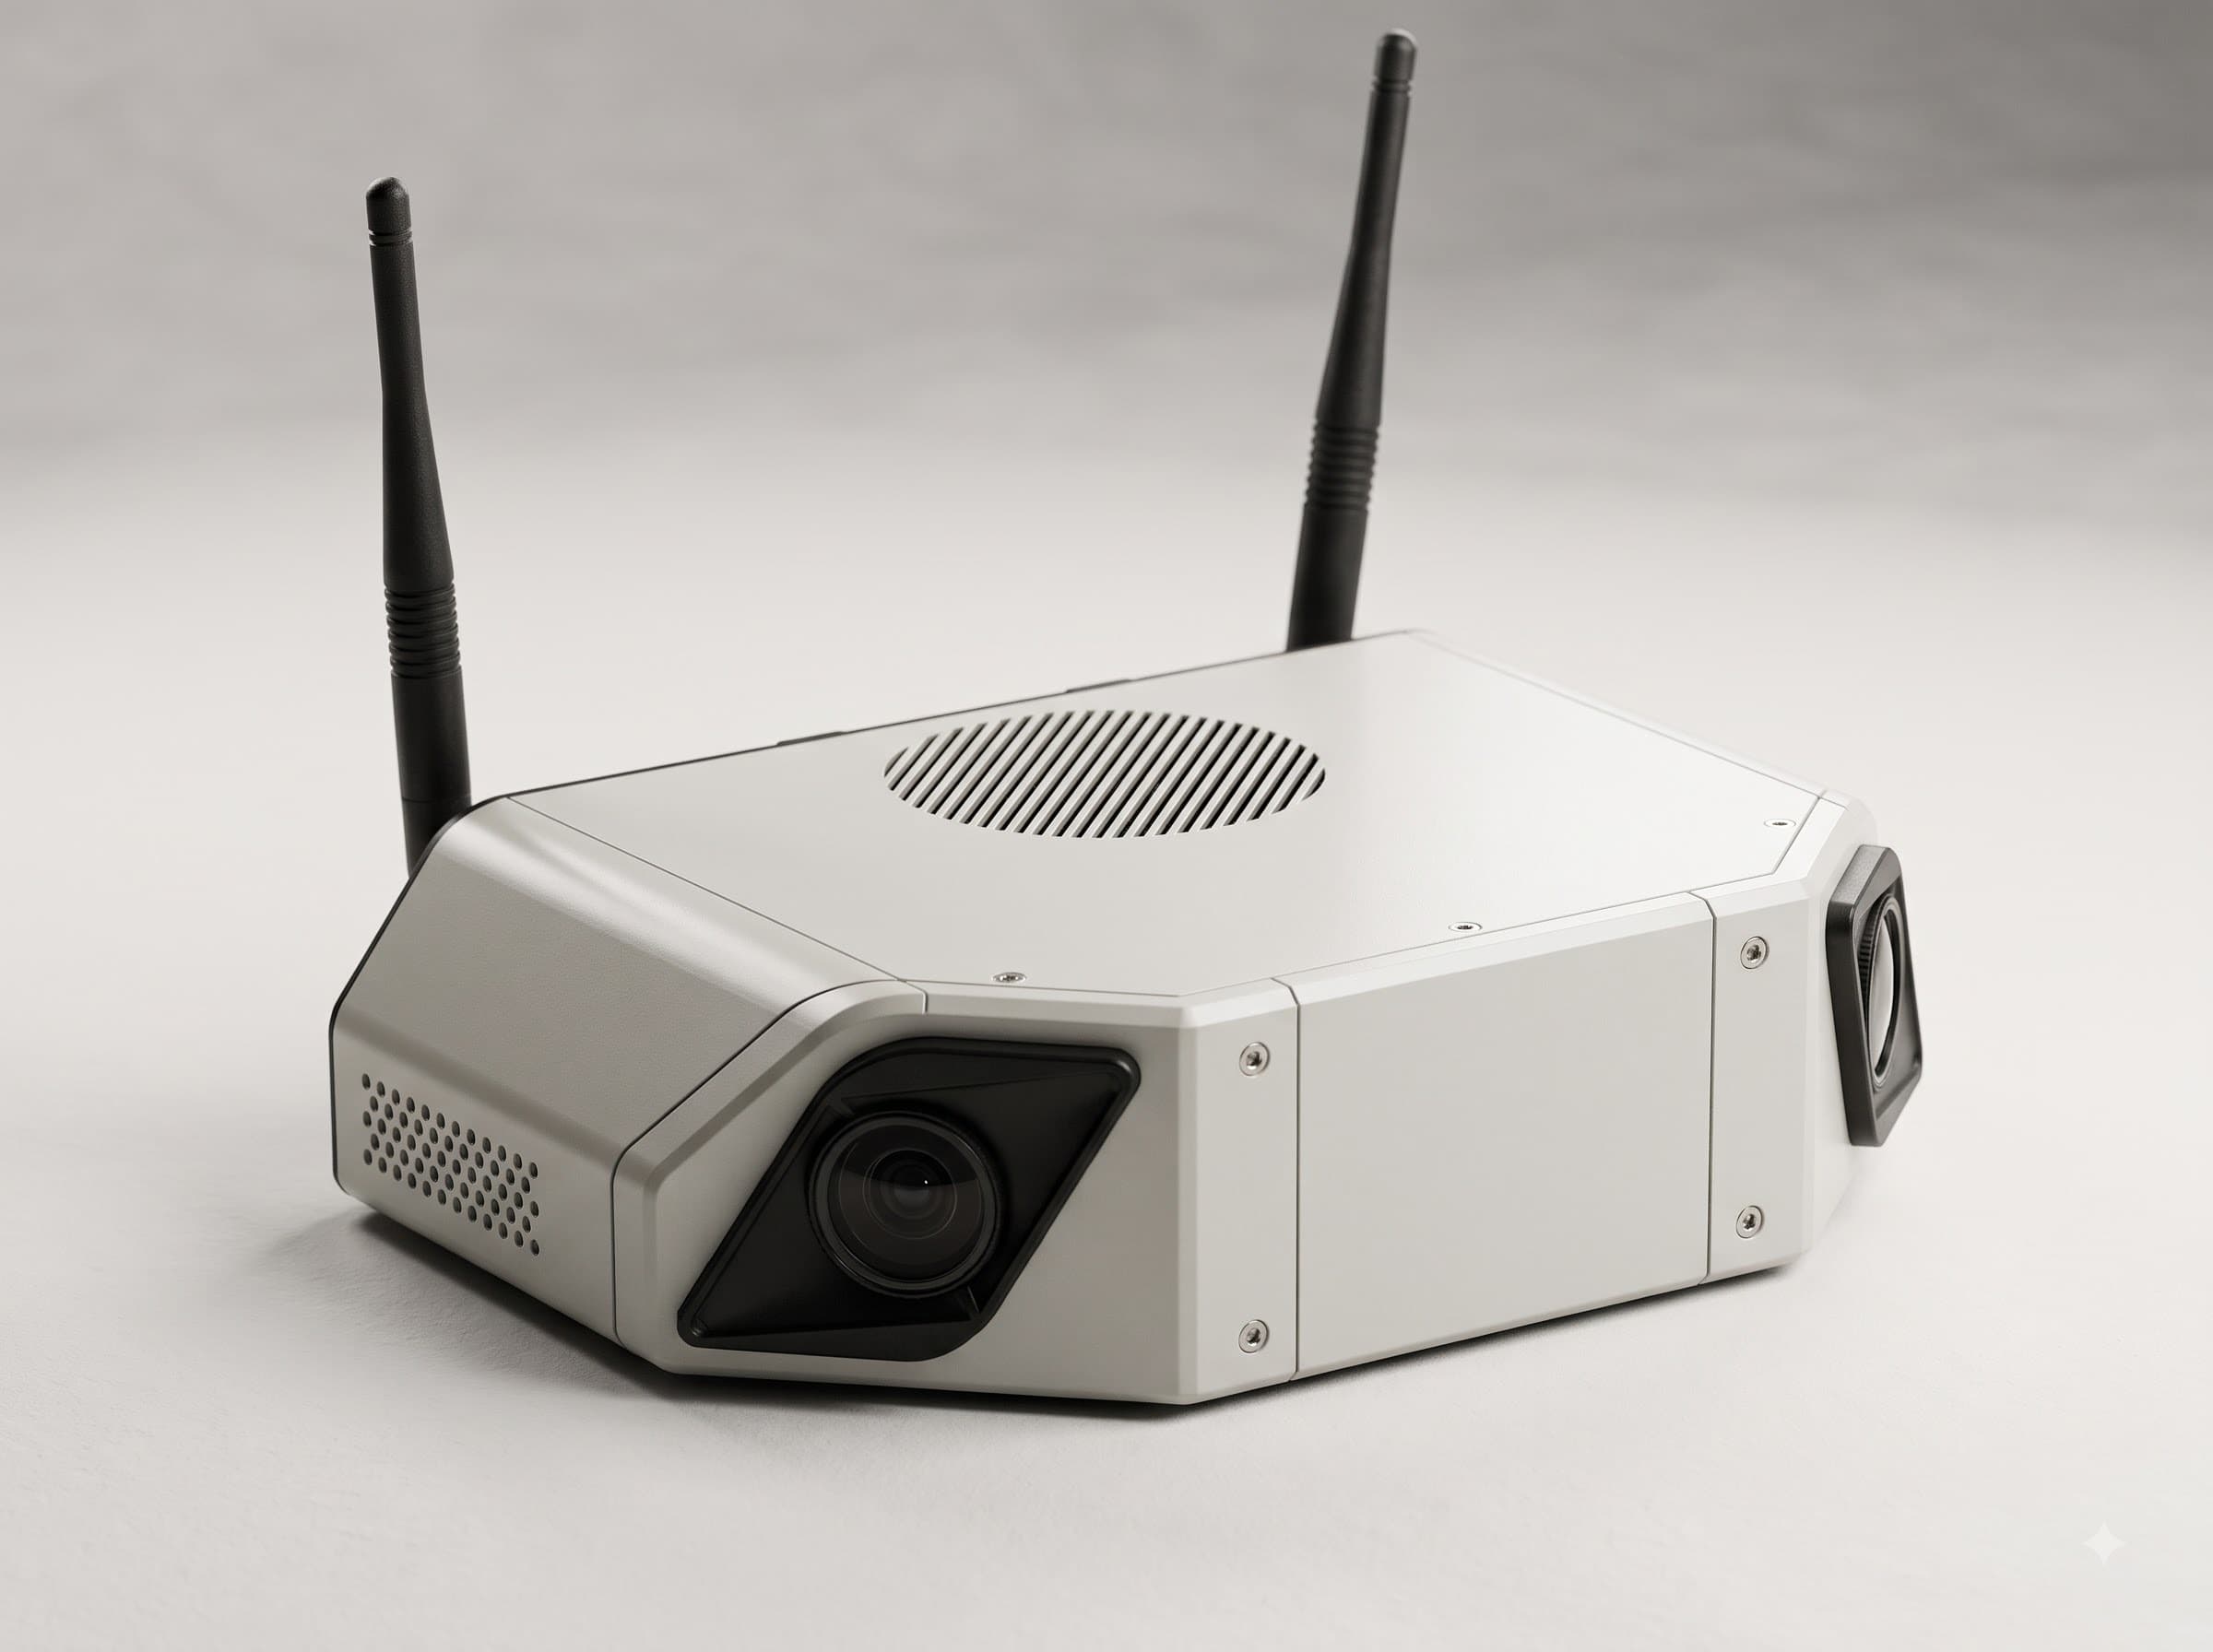
A compact add-on design mounts directly on a wide range of robot platforms. Standard interfaces make it easy to connect with your existing infrastructure.
Contact Sales about Navi-VPS
Analyze your site with our experts and design the right solution. We support you through every step, from consultation to on-site installation.